Snap Inc.
ML Research Engineer InternApplied research on L1 recommendation foundation models for 500M+ Snapchat user feeds.
Hello! I study computer science & math at Brown University.
I’m interested in reinforcement learning, world models, and efficient inference.
In industry and personal work, I've also deeply explored robotics, recommender systems, LLM post-training, and large-scale inference infrastructure. I love meeting new people, so feel free to say hello through email or LinkedIn below!
Applied research on L1 recommendation foundation models for 500M+ Snapchat user feeds.
Inference infrastructure optimization and kernel-agent post-training for ROCm.

Multi-agent reinforcement learning for collaborative aerial autonomy.

First SWE intern, working on AI and core product systems.
A Minecraft speedrunning agent.
Screenshots in, keyboard and mouse actions out.
Optimizing MiniOneRec inference with shared KV caches, decode replay, and folded attention heads.
868.8→114.8ms median
7.6× median speedup. Same rankings; separate recorded runs.
868.8→56.5ms median
15.4× median speedup. Rankings change; separate recorded runs.
Overall comparisons align the original released-loop timings with later optimized timings by cohort index. Same Office checkpoint, 500 users, RTX A6000, batch 1 and beam 50; measured in separate runs, not a new paired experiment. Speedups are ratios of the two measured medians, not multiplied per-step gains. The optimized FP32 run matches all 500 original ranking lists; scores are not bitwise identical. BF16 is experimental and changes rankings. Model loading, compilation, capture and warmup are excluded. Traces show 80-request windows in cohort order and retain all measurements. The individual optimization comparisons keep their own paired controls; the isolated BF16 comparison marks its 693.8 ms outlier above the 90 ms axis. Original timings · FP32 evidence · Precision & quality
Autonomous VRC routines in ROS 2 and Gazebo. The field, controller estimate, and command trace on one timeline.
6121C · Spin Up
Panoramic Alignment and View-based Evidence Recovery
Recovering occluded street-view pixels from neighboring panoramas, using feature matching and geometry.
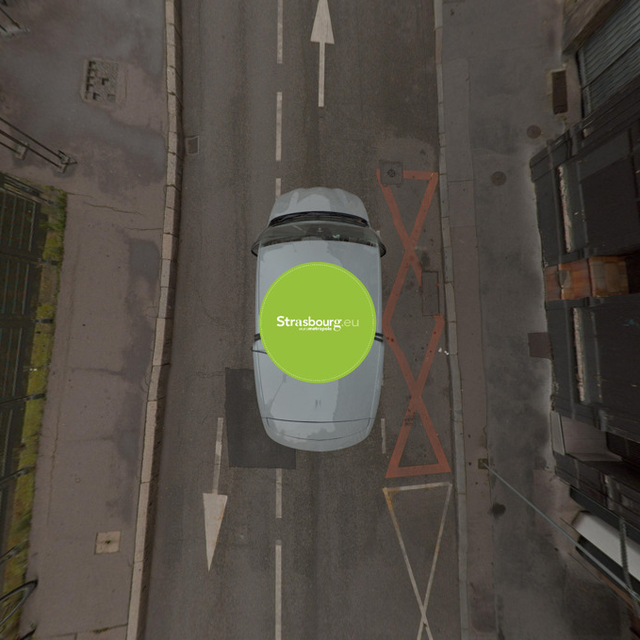
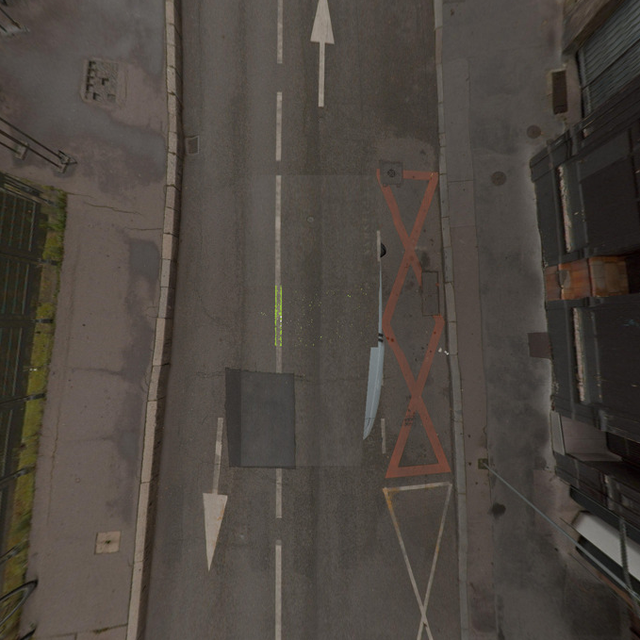
A · find the visible road pixels
Reconstructing Mercury’s southern gravity field with lunar transfer learning and topography.
Input · degree 25

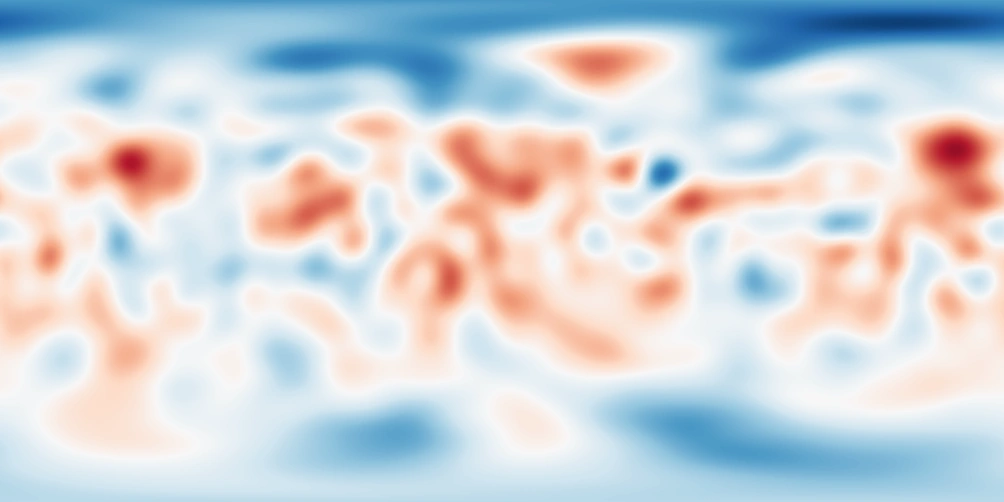
Southern detail is a model prediction.
A wildfire-response environment for multi-agent learning: fire spread, aircraft dispatch, suppression, and logistics.
Four stems, twelve pads, a step sequencer.
A music instrument for macOS.